Spiderman Einfach Malen . Heute könnt ihr in einem einfachen tutorial lernen, wie man spiderman zeichnet, ich hoffe ich kann euch mit diesem video dabei helfen, viel erfolg und natürlich viel. Der kreativität, die kinder beim ausmalen ihrer eigenen bilder von spiderman einsetzen können, sind keine grenzen gesetzt! Ausmalbilder kostenlos Mia and Me 2 Ausmalbilder Kostenlos from ausmalbilderkostenlos.org Die anleitung ist auch dabei. Der kreativität, die kinder beim ausmalen ihrer eigenen bilder von spiderman einsetzen können, sind keine grenzen gesetzt! Anschliessend die ganze tortenoberfläche (und nur die oberfläche) mit dünn ausgerolltem rotem rollfondant überziehen bzw.
Create Catkin Workspace Ros Kinetic. Install some prerequisites to use python3 with ros. 二、自定义服务数据的一般步骤 经过下面四个步骤,返回到workspace目录进行catkin_make,ros就能根据你的srv文件产生c++需要的源文件定义。 2.1 step1 创建一个srv 文件 srv 文件 每一行用段类型和段名组成,段类型有: int8, int16,
Radar and ROS Powered Indoor Home Mapping and Positioning Robot from www.electronicsforu.com
Play with the visualized robots; These instructions are for ros groovy and later. If you don't have the pi connected to the internet you could use the catkin commands to create the workspace on another conputer, then copy the files to a rpi.
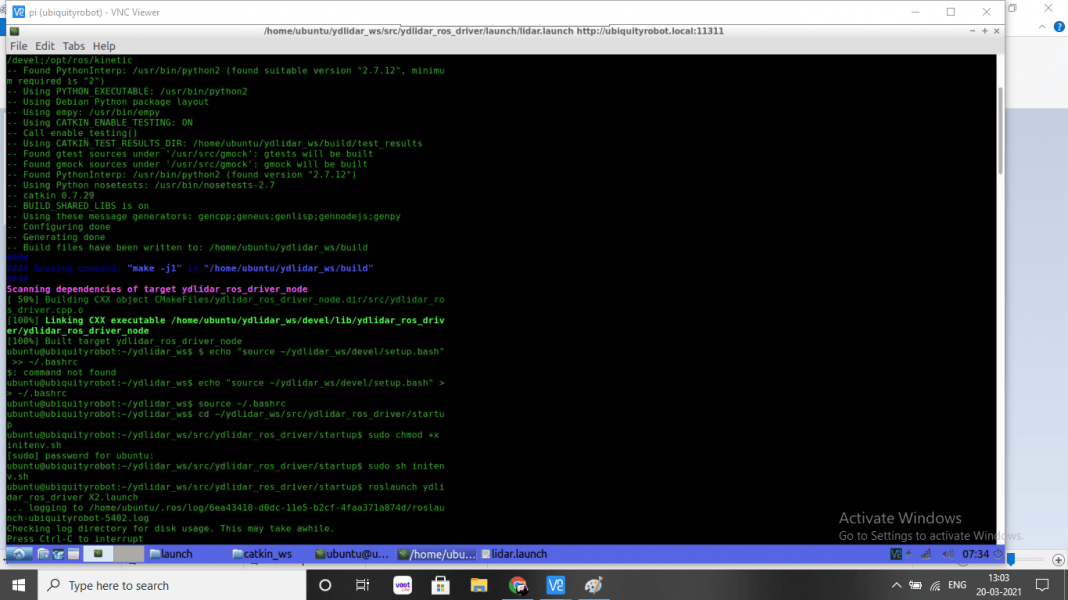
Let's Create And Build A Catkin Workspace:
Official ros packages for dji onboard sdk. If not already available, a catkin workspace can be created or transitioned from a catkin make workspace using catkin tools (or if using stock ros tools, see tutorial pages for creating a catkin workspace). If you don't have the pi connected to the internet you could use the catkin commands to create the workspace on another conputer, then copy the files to a rpi.
On Other Platforms You Will Find These Setup.*Sh Files Wherever You Installed Ros.
Launch the demo and configure the plugin; For ros fuerte and earlier, select rosbuild. Troy straszheim/straszheim@willowgarage.com, morten kjaergaard, brian gerkey
These Instructions Are For Ros Groovy And Later.
To recompile for python3 (melodic): Play with the visualized robots; 二、自定义服务数据的一般步骤 经过下面四个步骤,返回到workspace目录进行catkin_make,ros就能根据你的srv文件产生c++需要的源文件定义。 2.1 step1 创建一个srv 文件 srv 文件 每一行用段类型和段名组成,段类型有: int8, int16,
Create A Catkin Workspace And Download Moveit Source;
Issue is because tf2_ros was compiled for python2. The catkin_make command is a. Install some prerequisites to use python3 with ros.


Comments
Post a Comment